



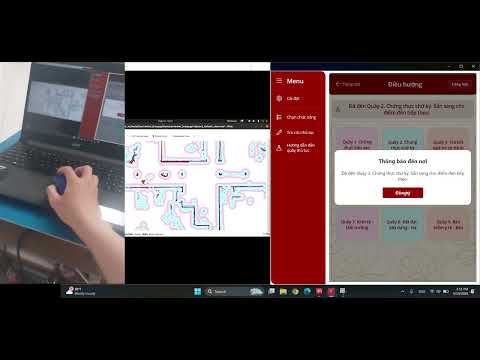
Xem thêm: Playlist các kết quả
- 🎓 Cử nhân Kỹ thuật Cơ điện tử, chương trình Kỹ sư tài năng, Đại học Bách Khoa TP.HCM (dự kiến hoàn thành chương trình học vào tháng 7 năm 2026)
- 🤖 Chuyên môn sâu: thiết kế, chế tạo và điều khiển robot di động thông minh, tập trung vào công nghệ ROS2 và hệ sinh thái robot hiện đại
- 💻 Kỹ năng nổi bật: ROS/ROS2 (Humble, Foxy, Noetic, Melodic), Python, C/C++, SolidWorks, AutoCAD, lập trình nhúng STM32/Arduino, mô phỏng xử lý robot trên Gazebo/Matlab
- 👨🔧 Kinh nghiệm thực tiễn: nhiều dự án thực chiến về AMR, SLAM, navigation, hardware abstraction, tích hợp cảm biến, chế tạo cơ khí, điện tử công nghiệp
- Thiết kế và tính toán động cơ, phát triển mô hình 3D và bản vẽ sản xuất cơ khí chính xác (laser cut, CNC, sheet metal)
- Điện/Điều khiển: xây dựng mạch điều khiển an toàn, tích hợp cảm biến nhiều loại (LIDAR, siêu âm, encoder, v.v.)
- Lập trình AMR với ROS2: sử dụng Lifecycle Node, ros2_control, custom hardware interface, Nav2, AMCL, SLAM Toolbox
- Kết quả: Robot vận hành tự động, xây dựng bản đồ môi trường, nhận biết vị trí, điều hướng an toàn, lập kế hoạch đường đi tối ưu
- Line Following & Color Sorting Robot
Thiết kế, chế tạo robot phân loại hàng hóa theo màu sử dụng Arduino và các cơ cấu truyền động - 3-DOF Robot Arm Simulation
Mô hình động học, điều khiển robot tay ba bậc tự do viết chữ tự động trên Matlab/SolidWorks
- ROS/ROS2: Node lifecycle, Nav2, Hardware Interface
- Kỹ thuật Robot di động: Kinematics, SLAM, localization, path planning, behavior tree, multi-sensor fusion
- Điện/Điều khiển: thiết kế mạch, lập trình nhúng STM32/Arduino/ESP, giao tiếp GPIO/UART/I2C/SPI
- Cơ khí: 3D modeling (SolidWorks, Inventor), sheet metal design, chế tạo 3D/laser/CNC
- Khác: Python/C/C++, Git, LaTeX, mô phỏng Gazebo/Matlab
- Email: duy.duongfebruary@gmail.com
- LinkedIn: bduykduongu
- GitHub: hcmutduygit
Xem chi tiết CV/tải bản PDF: CV LaTeX source